

Building a cobot cart: sturdy, smart and ready for the workplace
Why a cobot cart?
Would you like to deploy a cobot that is not fixed in one place, but moves flexibly with your production process? Then you need a stable and reliable cobot cart. But what points do you need to pay attention to during the design phase? This blog explains the main concerns as regards the frame, wheels, safety, couplings and positioning of the cobot.
Discover how Sirris and KU Leuven designed a robust, reconfigurable cobot cart for sheet metal applications. Download the COOCK+ ROBUST casebook for a practical, step-by-step guide to build your own cobot.
Frame: welded or modular?
The backbone of your cobot cart is the frame. There are two options: a welded steel frame or a profile construction in aluminium.
Welded steel frame:
- Very sturdy and stable thanks to heavier weight
- Ideal for fixed setups and harsh working environments
- Customisation requires welding expertise
Aluminium profile construction:
- Faster to build and easier to adapt afterwards
- Relatively cheap (around € 5,000 for our demonstration model)
- Lighter and therefore slightly less stable
Your choice depends on the way you want to use it and how much you want to be able to modify the design later.
Important: there are electrical components built into the cart. These include both high- and low-voltage components. We chose to keep these separate to ensure safety when working on the low-voltage components (which is more frequent). The compartments in the cart where these components are located must also comply with the standards for building an electrical cabinet
Wheels: drive or non-drive?
The type of wheels determines how mobile your cobot cart is and the price:
- Non-drive wheels are the cheapest and suffice if the trolley does not need to be moved frequently
- Drive wheels are a good choice if the trolley needs to be moved frequently especially on sloping floors, they do however, require a battery
- Autonomous navigation based on AGV technology is technically feasible, but is currently too expensive for common SME applications
- The number of wheels is another factor to be considered. Tricycles are more stable when stationary, but slightly less so when moving, four-wheelers are easier, but can wobble on uneven floors
So make an informed choice. Depending on the alignment method chosen, stabilising feet or a docking mechanism are required to prevent the cart from moving while work is ongoing.
Worktop, grippers and couplings: think of the future
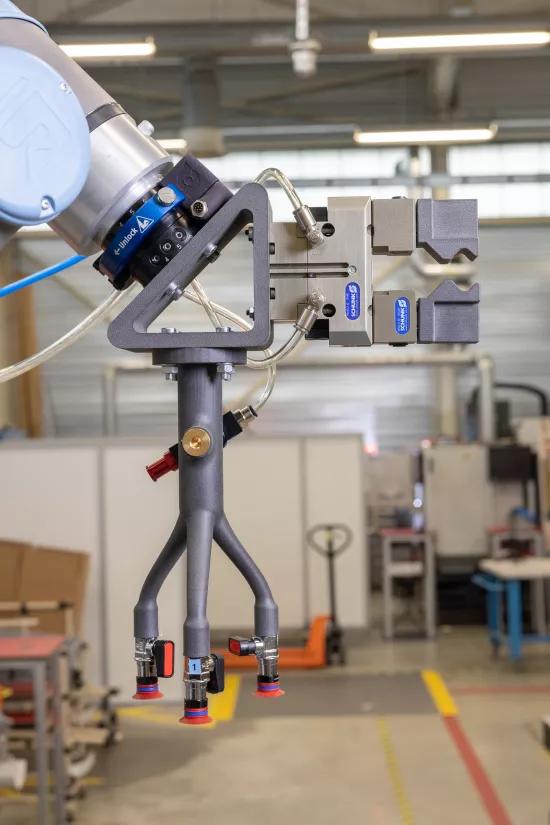
The worktop should be robust and suitable for clamping workpieces. Aluminium is often sufficient, but in heavy industrial environments it is worth opting for a harder material. Making space for a valve island is also important, even if your current applications do not require pneumatic components. Plan for the future and install it now. This way, your cart can be reconfigured when necessary.
Preferably use quick-disconnect connectors for power, safety and location coding. Avoid thick cables with multiple discrete I/Os. Instead, opt for fieldbus communication or wireless systems. They require a machine-side interface, but make disconnection so much easier and safer.
Cobot: positioning and range
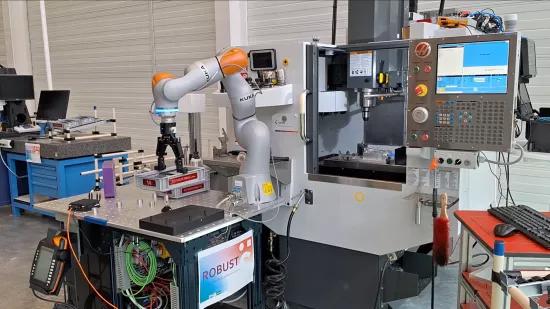
The cobot itself is mounted on an intermediate plate on the worktop. (The demonstration cart is equipped with either a KUKA LBR iiwa or a Universal Robots UR10 but other cobots are, of course, also possible). This makes the system suitable for all types of cobots. The positioning of the cobot on the cart is crucial. A central position provides more stability, but sometimes limits the range of the cobot. Depending on the application, you need to find a compromise between range, stability and accessibility. In addition, be sure to note the difference between a cobot's maximum range and maximum payload: the two rarely coincide. The maximum advertised payload is rarely achievable when the cobot is at the extreme point of its range. If an application requires the cobot to operate at the limits of its range, keep in mind that the maximum payload will not be as large as the advertised payload.
Communication and safety: keep it clear
Cobot cart projects often come up against limitations in the cobot's standard I/Os. An extension with a gateway module (e.g. a RevPi) helps to convert protocols and reduce physical connections. This keeps the cabling clear and the connectors small. For safety reasons, the use of a safety PLC and scanner (e.g. from Sick) is highly recommended, ensuring that the cobot stops as soon as an operator enters the safety zone.
Modular base, thoughtful design
So a good cobot cart is stable, reconfigurable and safe.
It combines:
- A rigid or flexible frame
- The right type of wheels for your application
- A well-chosen worktop with forward-looking features
- Strategic positioning of the cobot
- And secure, modular communication components
ROBUST | Reconfigurable cOBotic prodUction AsSistanT
ROBUST helps sheet metal suppliers with high-mix-low-volume production to automate repetitive tasks using mobile, reconfigurable cobots. Because small batches and changing orders often stand in the way of standard automation, the project uses demonstrators to show how cobots can be flexibly deployed for a variety of tasks such as pressing, welding, deburring, and gluing. ROBUST offers companies practical tools and knowledge to work step by step toward more efficient, (semi-)automated production.
Discover the other parts of the Cobot cart manual
Part 2: how do you ensure that your cobot cart is perfectly aligned?
Part 3: how does a cobot cart communicate with its environment?
Part 4: smart cobots thanks to 3D computer vision
Part 5: from workbench to mobile cobot assistant: make your production flexible
Part 6: making a mobile cobot plug and play using real-time pose tracking
Part 7: safety when using movable cobot cells: how ROBUST helps companies comply with the regulations
Part 8: smarter programming with cobots: how ROBUST is focusing on programming ease for flexible automation


